Multi-sensor fusion
LiDAR, mmWave radar, ultrasonic and camera streams are hardware-timestamped, extrinsically calibrated to a common vehicle frame and aligned to a single time base, then fused into a shared spatial representation.
OmnixDrive performs intrinsic and extrinsic calibration and temporal alignment across LiDAR, mmWave radar, ultrasonic and camera streams, fuses them into a shared spatial representation, and trains hardware-aware models for on-vehicle inference on automotive SoCs.
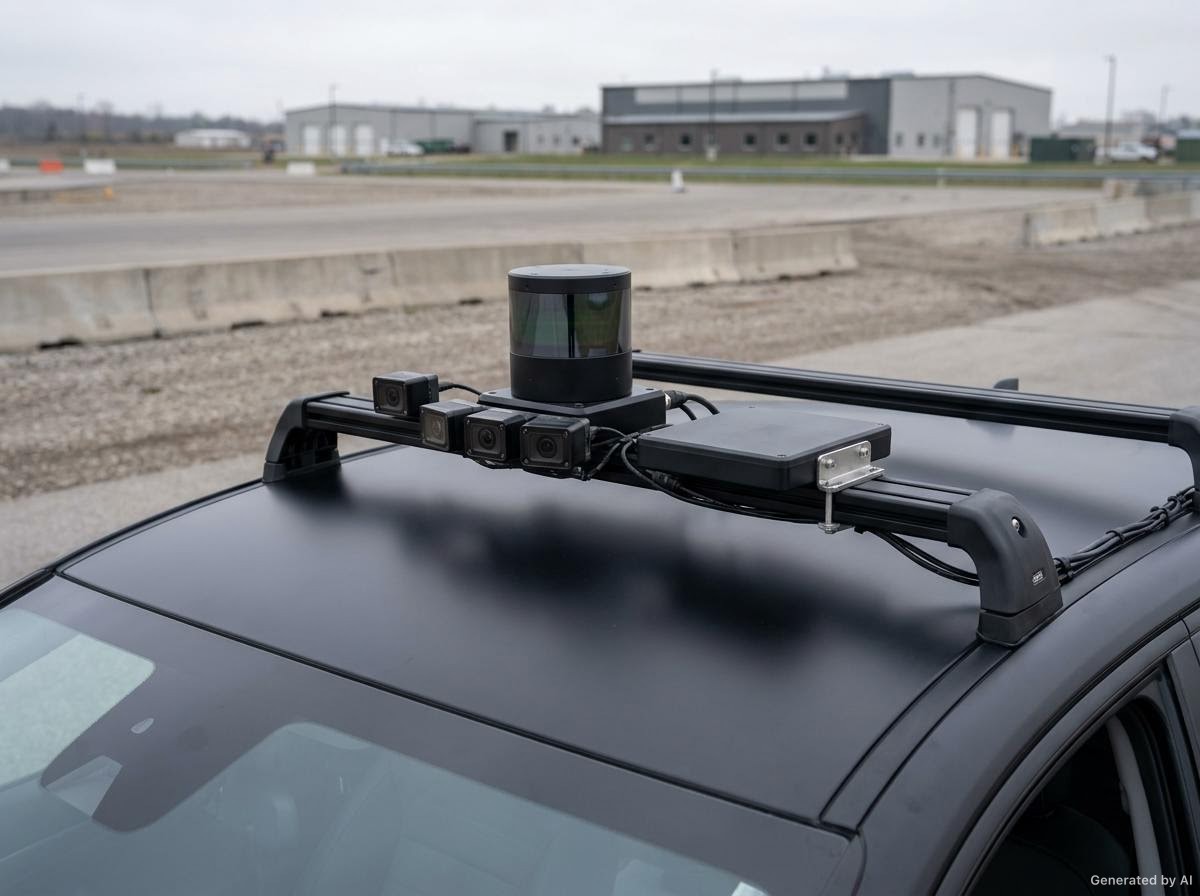
The platform covers sensor calibration, temporal alignment, multimodal fusion, hardware-aware model training and deployment on automotive SoCs.
LiDAR, mmWave radar, ultrasonic and camera streams are hardware-timestamped, extrinsically calibrated to a common vehicle frame and aligned to a single time base, then fused into a shared spatial representation.
Perception and planning models are trained against the fused representation, then quantised, distilled and pruned to meet a fixed latency, memory and power budget on the target automotive SoC.
Fleet data returns to the pipeline: auto-labelling, calibration drift monitoring and versioned datasets keep the model bound to the sensor configuration it was trained on.
Our development process is defined against the standards regulated automotive programmes require — functional safety, software process, information security and data protection.
Perception runs on the vehicle; training runs in your data centre, a private cloud or ours.
Technical platform, programme applications, company information, careers and contact details.
Company profile, engineering scope, operating principles, team and locations.
Read about OmnixDrive 02The fusion pipeline, the on-device runtime and the deployment models we support.
See the platform 03OEM and Tier-1 programmes, sensor-supplier evaluation, and the engagement models available.
Review solutions 04Engineering disciplines, working model, employment terms and application details.
View open roles 05Business, technical, partnership, press and recruitment contact details.
Contact us
Founded in Singapore in 2026, OmnixDrive develops multi-sensor perception pipelines and dedicated on-vehicle AI models for autonomous driving. Its engineering scope covers multimodal perception, sensor calibration and geometry, model compression, embedded inference and dataset operations.
Intrinsic and extrinsic calibration, coordinate transformation and time-base alignment are validated before model training begins.
Model training and optimisation are performed against the latency, memory and power budgets of the target automotive SoC.
Accuracy is reported per sensor and per scenario, with model, dataset and calibration versions retained for regression analysis.
A technical consultation covers the sensor configuration, calibration chain, target automotive compute and scope of an initial deployment phase.